关于 LEMO
An out-of-the-box dual-arm desktop platform for embodied AI development, covering teleoperated data collection through model deployment and validation.
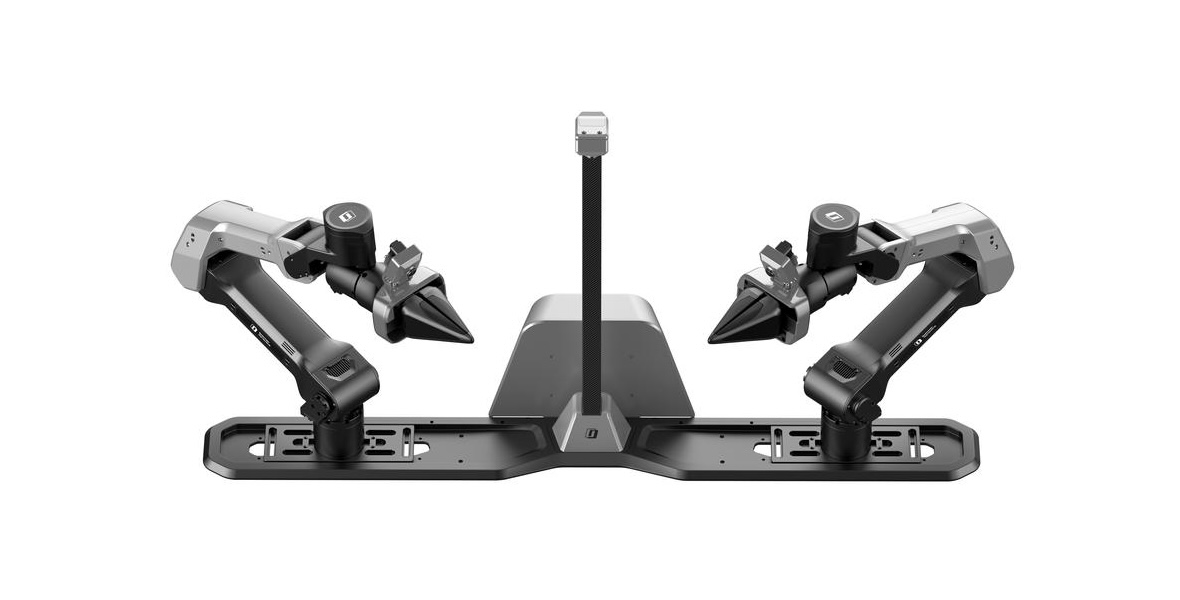
Welcome to the Galaxea developer community, and thank you for becoming a user of the LEMO dual-arm desktop operation platform. This manual will help you complete product unboxing, mechanical installation, cable connection, and getting the whole system up and running, and further introduce the LEMO hardware configuration, teleoperation, data collection, model deployment verification, and the use of development interfaces.
1. Product Introduction
LEMO is a dual-arm development platform for embodied intelligence developers, integrating teleoperation, data collection, model deployment verification, and secondary development, and covering the entire embodied intelligence development workflow from data collection and model training to inference and deployment. The product highly integrates dual A1Z robotic arms, G1Z grippers, a multi-view synchronized vision system, and the LEMO-CCU control box. It supports out-of-the-box use, quick assembly and disassembly, and flexible placement, helping universities, research institutions, and robotics development teams efficiently conduct dual-arm operation research and embodied application development.
2. Safety Instructions
Before using the LEMO dual-arm desktop operation platform, please carefully read the following safety instructions to ensure the safety of operators and personnel nearby, and to ensure the normal operation and long-term stable use of the device.
2.1 Operational Safety
- Qualification requirements: Operators must receive necessary product training and be familiar with LEMO's installation procedures, operation methods, safety regulations, and emergency response measures to ensure they have the ability to operate the device correctly and safely. Personnel who are not yet familiar with this manual should be guided and supervised by experienced personnel when approaching or operating the device.
- Operating environment: Please provide a workspace that meets the requirements for LEMO, ensuring that the installation platform is flat and stable, with no flammable or explosive materials, liquids, strong magnetic field interference sources, or other potential hazards nearby. The device should be placed in a clean, dry, and well-ventilated environment to avoid device failures or safety accidents caused by environmental issues.
- Operating standards: Please strictly follow the steps and methods specified in this manual. Do not touch the robotic arms, grippers, camera stand, or other moving parts at will while the device is running, and do not adjust key settings such as joint parameters, speed, acceleration, or safety limits without authorization, to avoid device damage or personal injury.
2.2 Device Safety
- Power safety: Use a power adapter that meets the device requirements, ensuring that the power supply voltage is stable within the specified range (24 V), to avoid device damage caused by voltage fluctuations. Also, regularly inspect the power cable and related connection points to ensure they are intact and firmly connected.
- Structural fixation: Before each use, check whether the operation platform base plate, left and right robotic arms, camera stand, grippers, and related fasteners are securely installed. If you find a loose base, structural shaking, or missing fasteners, stop using the device and complete the inspection and repair.
3. Emergency Stop and Remote Control
- The emergency stop button can immediately cut off the device's power supply.
- The remote control enables remote pause, stopping the LEMO dual-arm motion.
4. Product Dimensions
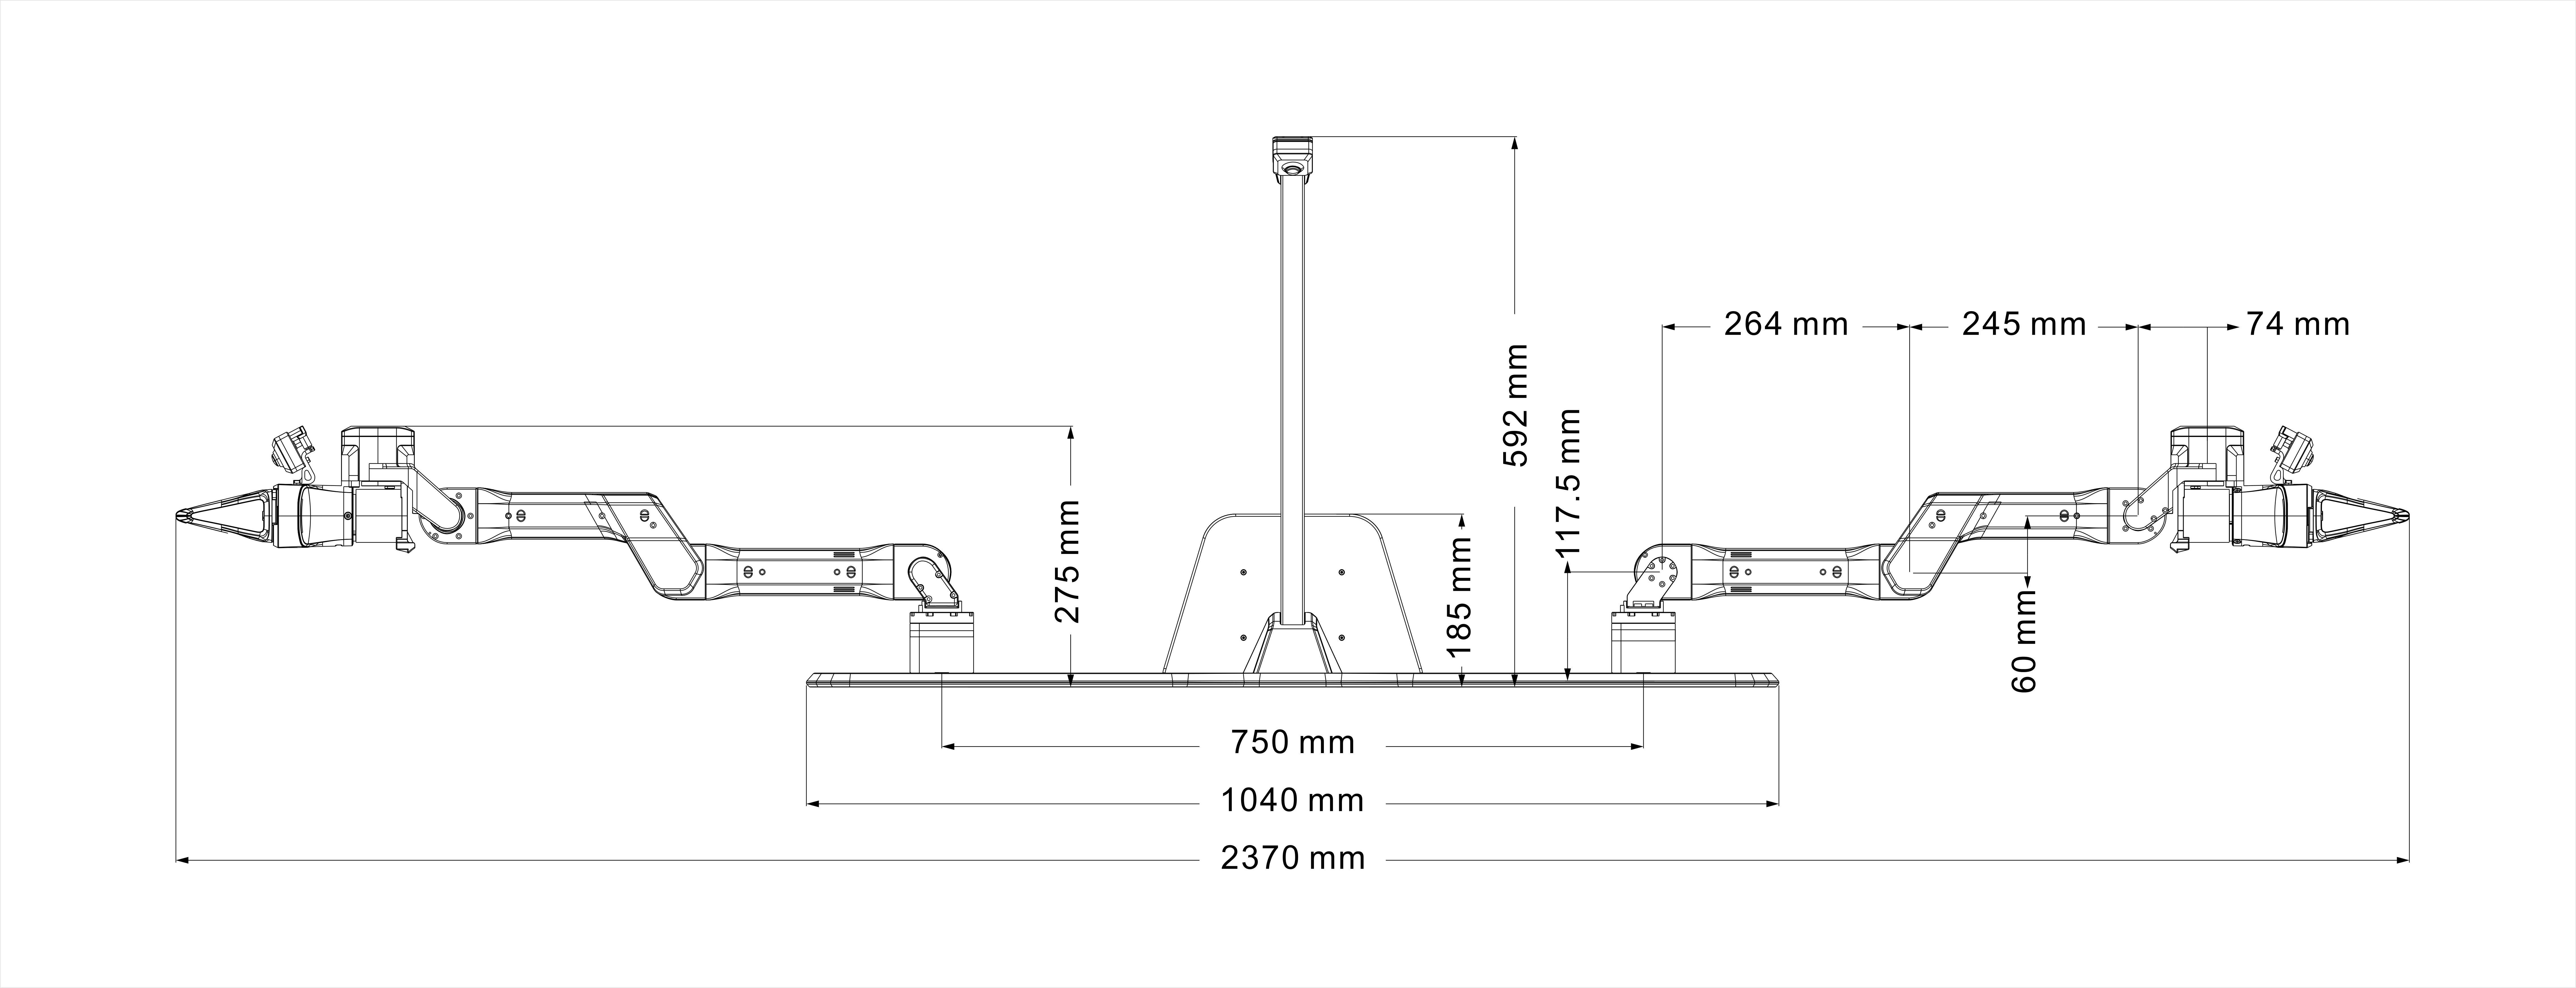
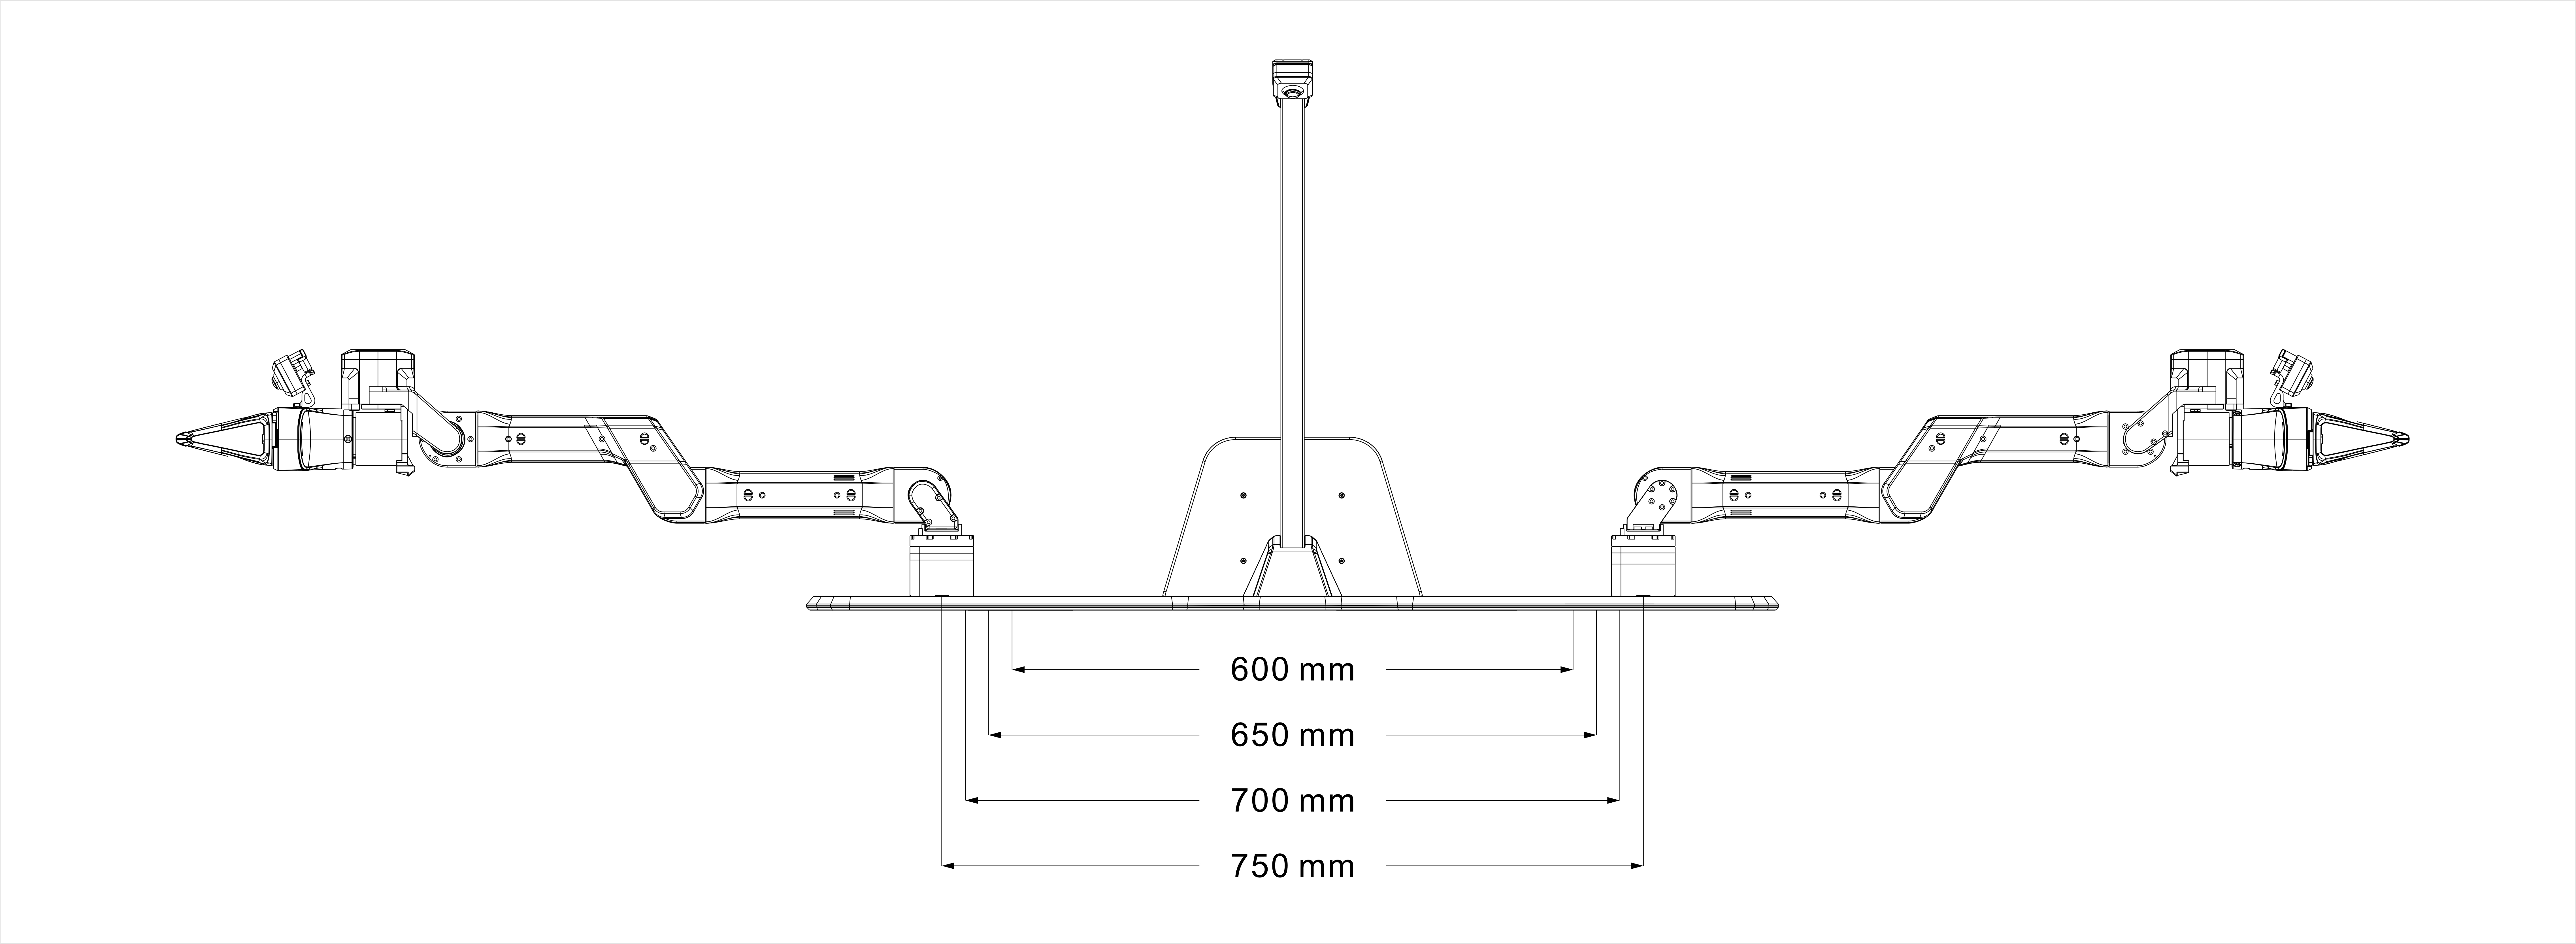
5. Technical Specifications
| Parameter | Key Indicator |
|---|---|
| Overall degrees of freedom | 14 DOF |
| Single-arm rated load (excluding end effector) | 3 kg (per arm) |
| Single-arm peak load (excluding end effector) | 5 kg (per arm) |
| Single-arm repeat positioning accuracy | ± 0.1 mm |
| Gripper rated gripping force | 150 N |
| Maximum gripper opening/closing speed | 108 mm/s |
| Fastest full-stroke gripper opening/closing time | 0.4 s |
| Overall weight | 18 kg |
| Packaged weight | Carton: 24 kg Flight case: 30 kg |
| Overall dimensions | L1040 * W565 * H592 mm |
| Maximum reachable space | L2370 * W900 * H912 mm |
| Controller | RK3588 - CPU:4*Cortex-A76 + 4*Cortex-A55 - GPU:Mali-G610 MP4 - NPU:6 TOPS computing power |
| Memory | 8 GB LPDDR4X |
| Storage (supports up to 512 GB TF / microSD card expansion) | 64 GB eMMC |
| Communication interface | CAN |
| Rated voltage | 24 V |
| Current | 30 A |
| Interfaces | - 1000 Mbps RJ45*2
- HDMI 2.1 OUT*2 - USB3.0 Type-A*2 (wrist camera interface) - USB3.0 Type-C*1 (head camera interface) - USB2.0 Type-A*2 - Micro SD*1 - WIFI 6E AX210 |
| Gripper stroke | 0 ~ 100 mm |
5.1 A1Z Robotic Arm
The A1Z robotic arm has 6 joints in total, with a maximum rotation angle of 240°. For details, see the A1Z User Manual。
| Joint | Rated Torque (Nm) | Peak Torque (Nm) | Rated Speed (rpm) | Peak Speed (rpm) | Software Range(°) | Hardware Range(Limit Protection)(°) |
|---|---|---|---|---|---|---|
| Joint 1 | 20 | 50 | 54 | 60 | [-120°, 120°] | [-130°,130°] |
| Joint 2 | 25 | 50 | 54 | 60 | [0°, 180°] | [0°,202°] |
| Joint 3 | 20 | 50 | 54 | 60 | [-180°, 0°] | [-200.38°,0°] |
| Joint 4 | 9 | 25 | 36 | 52 | [-85°, 85°] | [-91.88°,110.38°] |
| Joint 5 | 3.5 | 7 | 100 | 150 | [-85°, 85°] | [-90°,90°] |
| Joint 6 | 3.5 | 7 | 100 | 150 | [-115°, 115°] | [-120°,120°] |
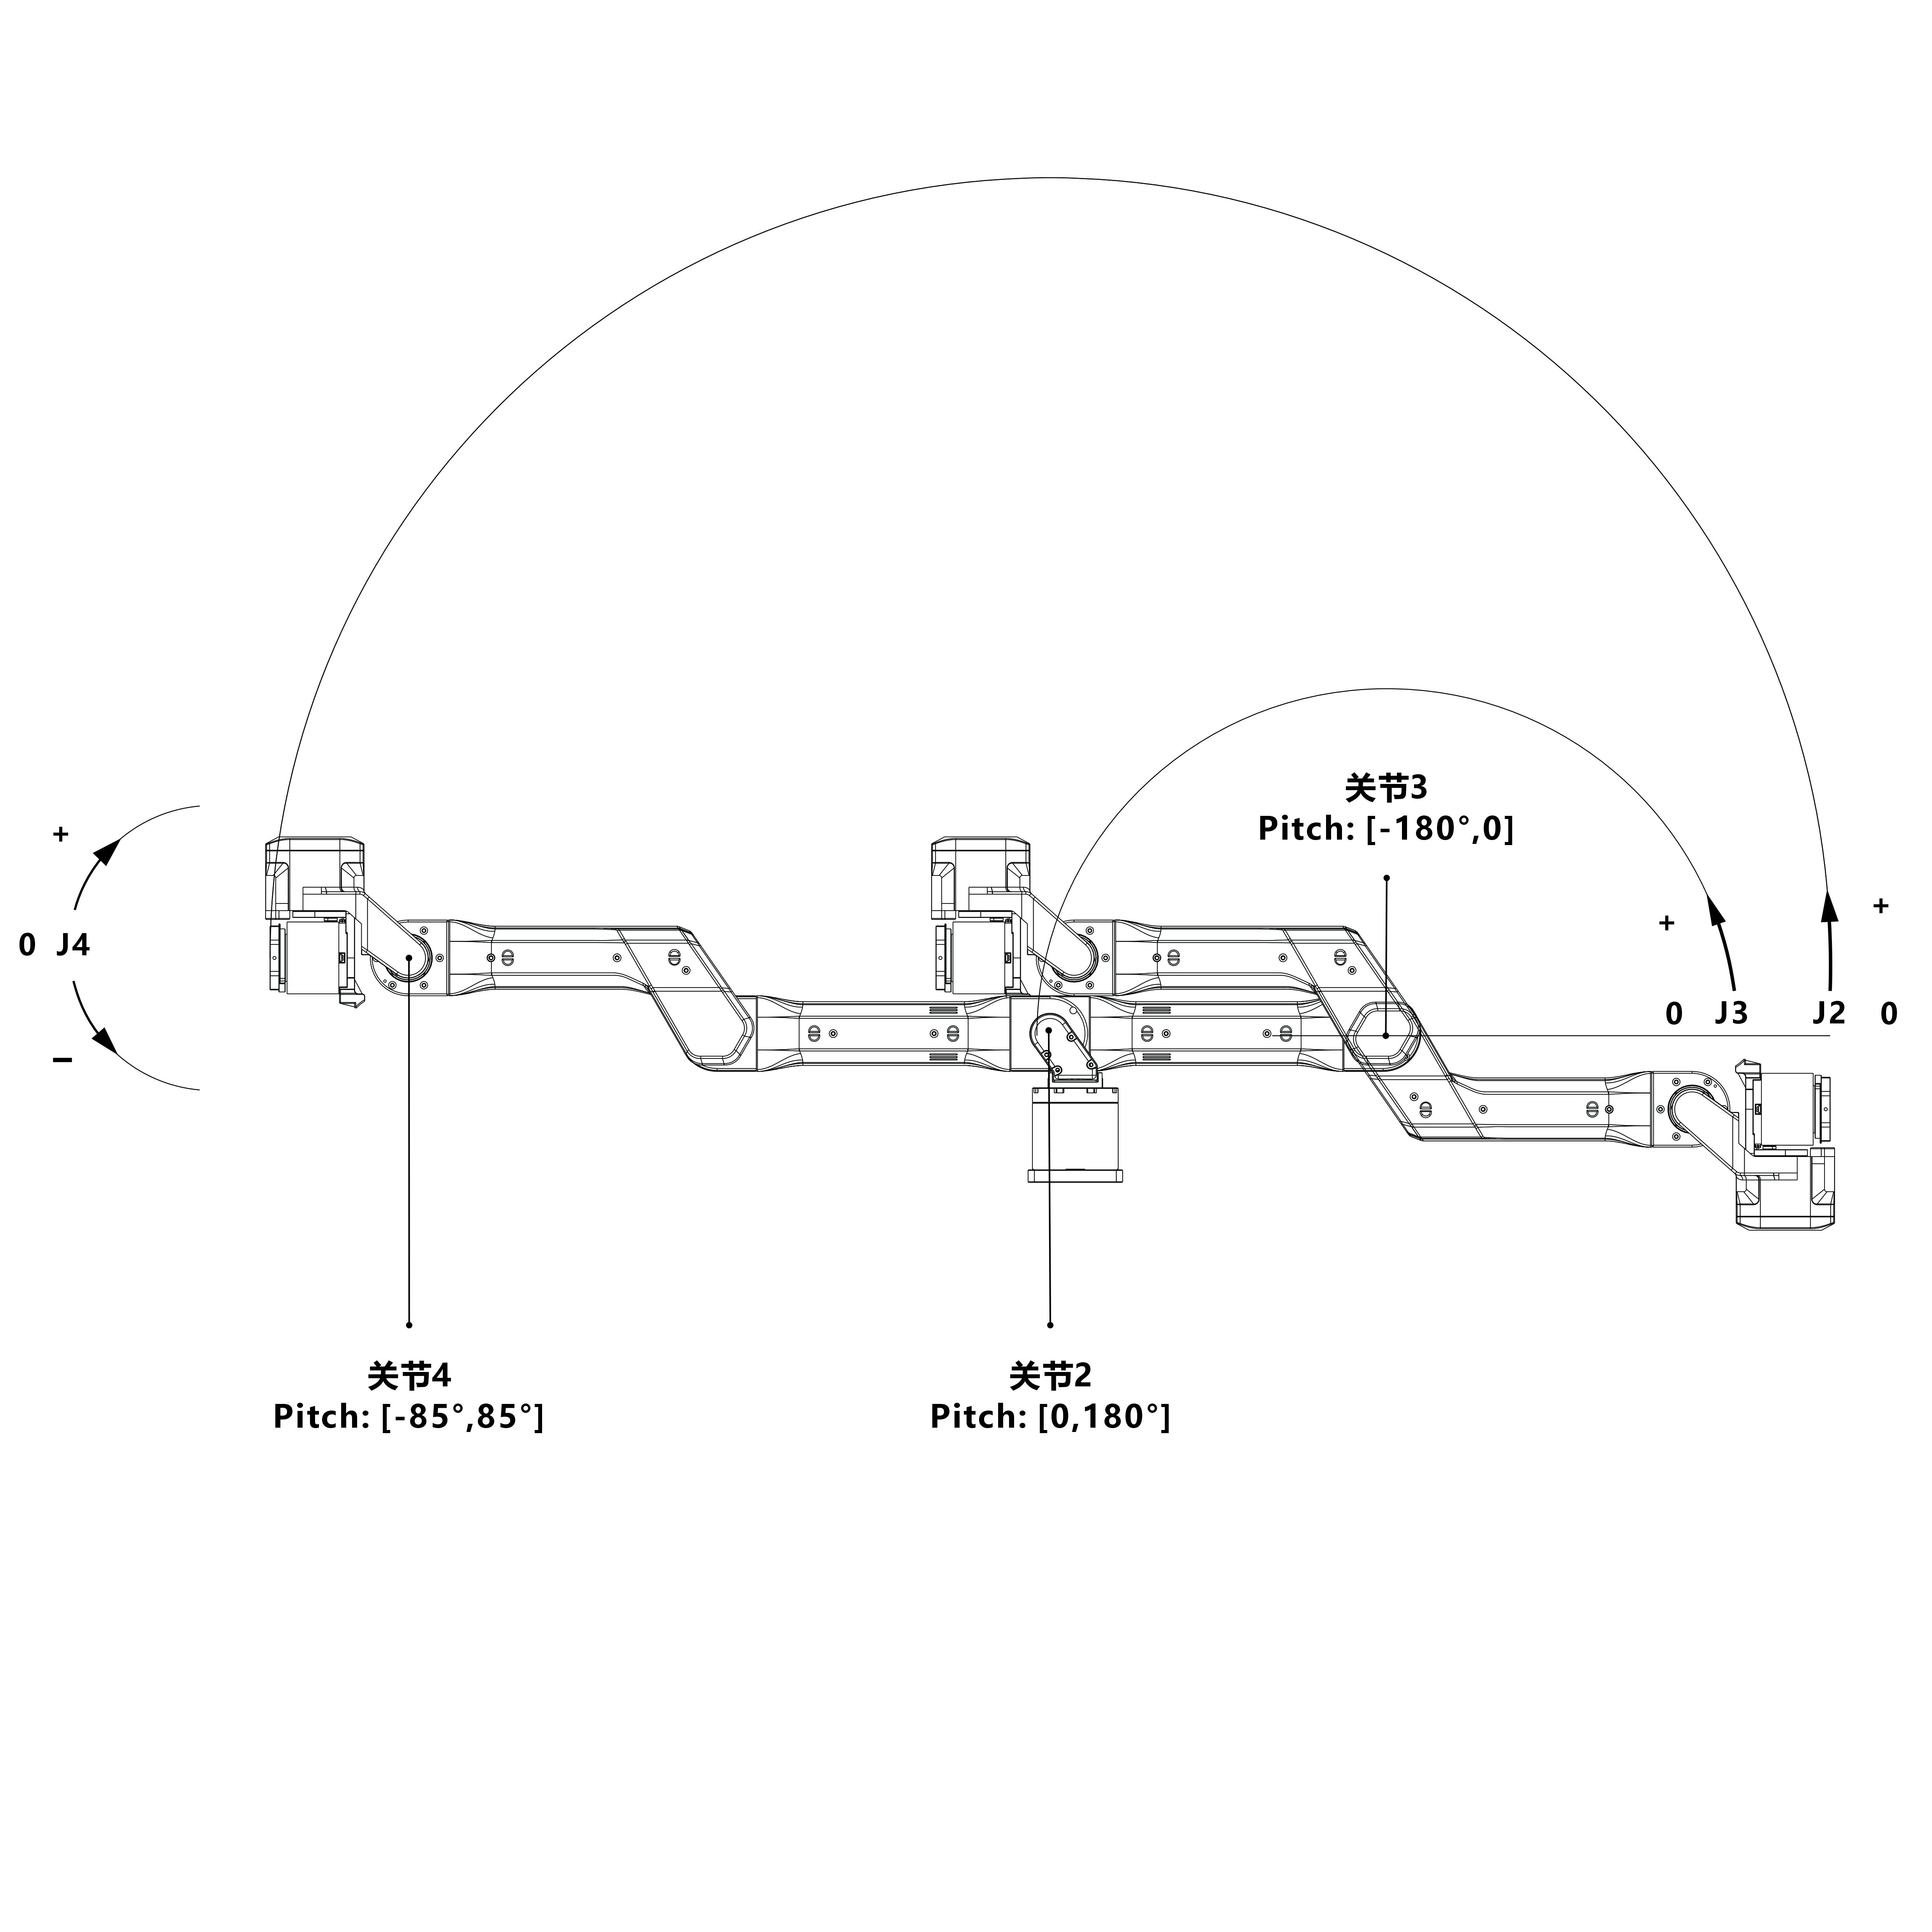
The working ranges of each joint of the robotic arm are shown in the figure below:
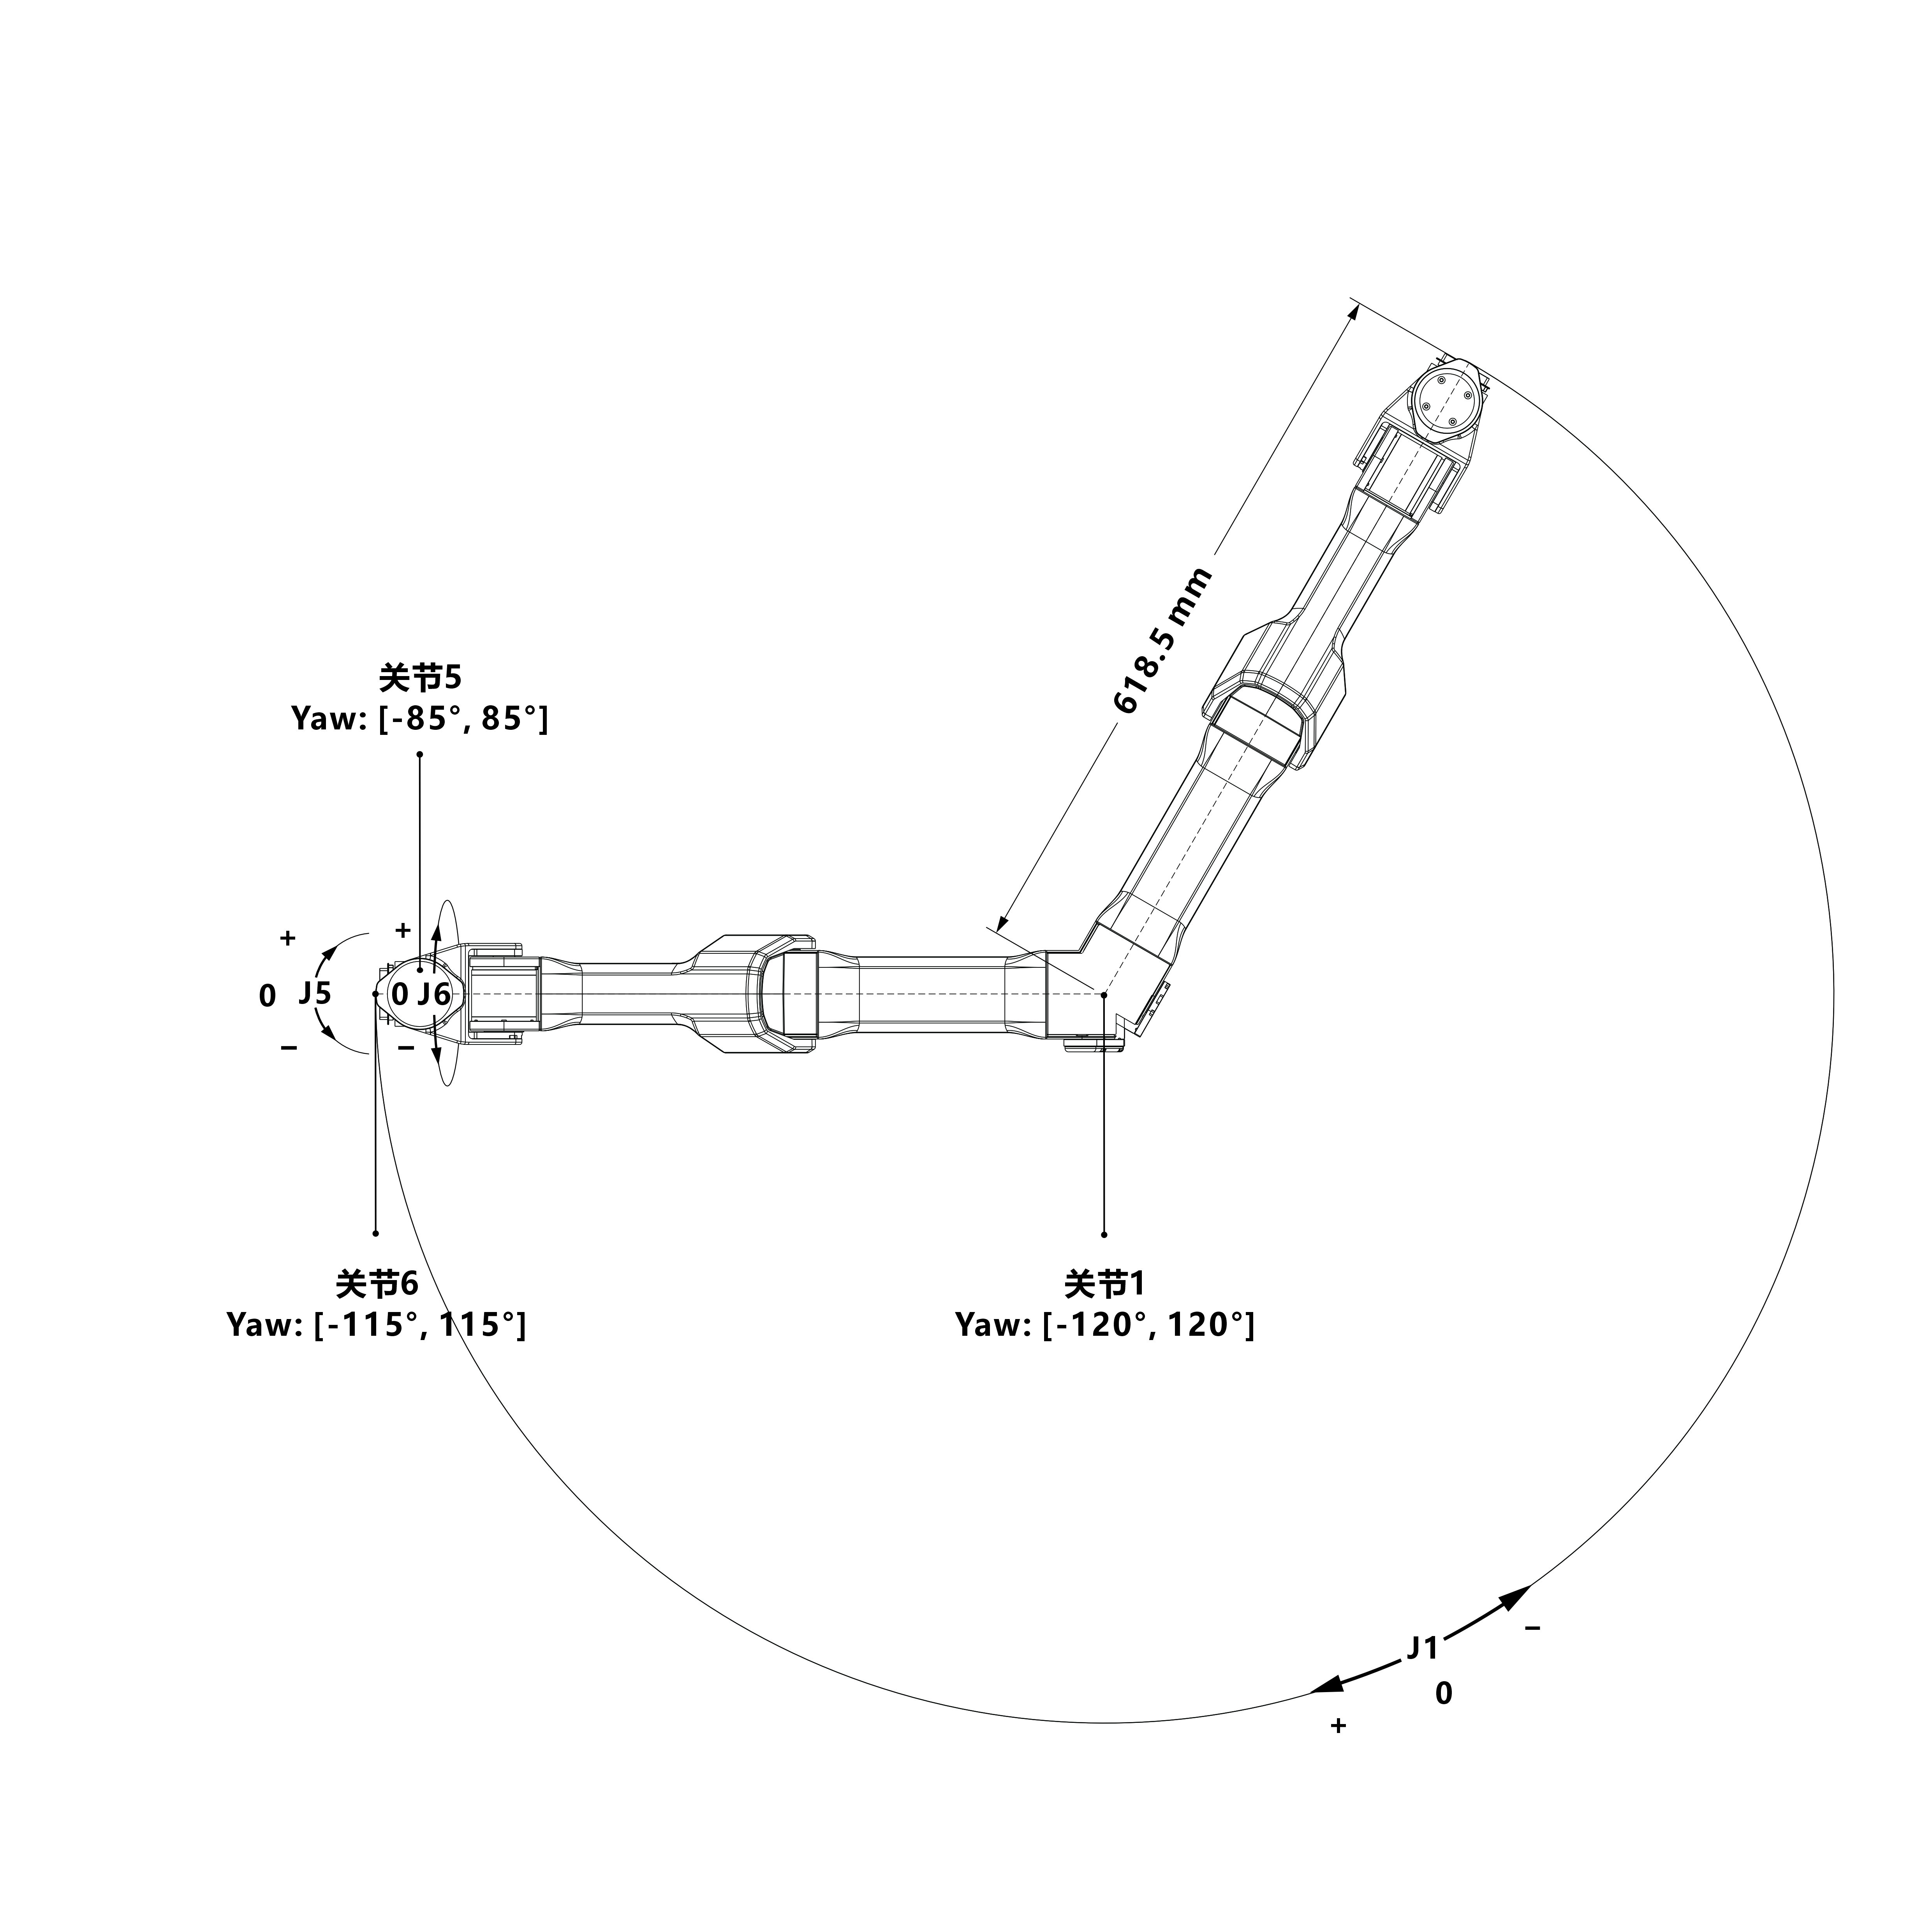
- The maximum rotation angle of robotic arm joint 1 in the Yaw direction is 240 degrees, with a rotation radius of 618.5 mm;
- The maximum rotation angles of joint 2 and joint 3 in the positive Pitch direction are both 180 degrees;
- The maximum rotation angle of joint 4 in the Pitch direction is 170 degrees.
- The maximum rotation angle of joint 5 in the Yaw direction is 170 degrees;
- joint 6 in the Roll direction is 230 degrees.
5.2 Galaxea G1Z Gripper
Galaxea G1Z is a self-developed parallel gripper equipped with one joint motor and two-finger fixtures.
| Gripper | Value |
|---|---|
| Gripper Length | 190 mm |
| Gripper depth | 104 mm |
| Gripper width | 109 mm |
| Gripper stroke | 0 ~ 100 mm |
| Gripper rated gripping force | 150 N |
| Maximum opening/closing speed | 108 mm/s |
| Fastest full-stroke opening/closing time |
6. Getting Help
If you encounter any problems while using LEMO and need immediate assistance, please email us at support@galaxea-dynamics.com. Our professional technical support team will be dedicated to assisting you, answering your questions, and helping you resolve various technical issues.